Search robots for house fires
Know the house before you walk in.
Robot dogs map a burning house, find the people inside, and tell the crew where to go.
Pick a house. Send in the dogs.
CinderEmber
LiveThree-bed ranch
Through the smoke
Colour sees smoke. Heat sees people.
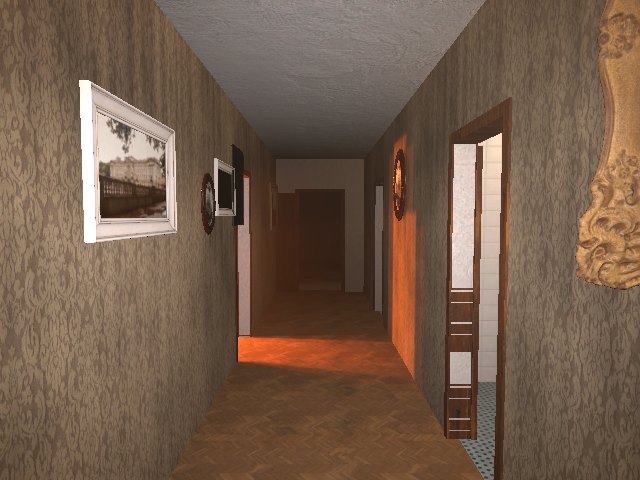
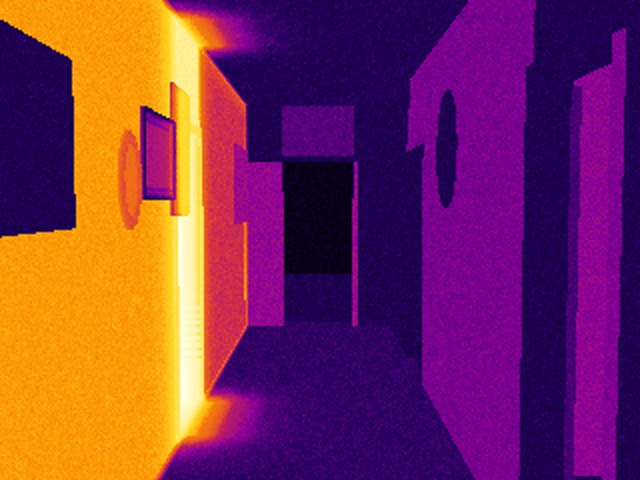
ColourHeat
Top view
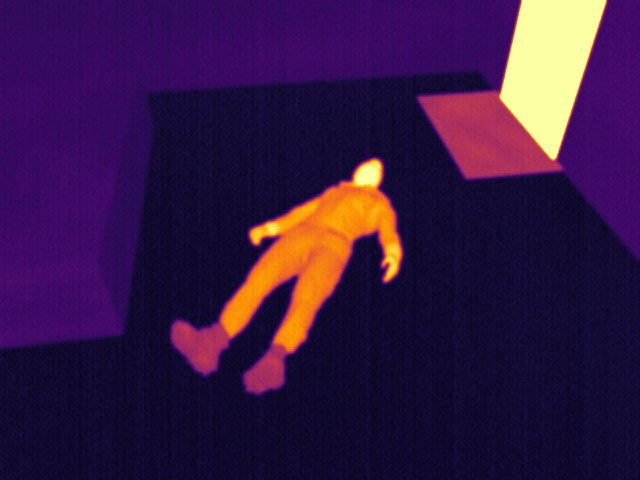 Real OpenCV 5 output
Team
Every dog maps. The radio shares it.
Each dog's map0.0 s
- Dog A
- Dog B
- Dog C
Lead dog
Simplified model.
2 sbetween radio messages
12 mradio range
1 wallit gets through
How they walk in.
Two dogs, no driver. Each one picks the next room on its own.
00 rooms
Visual SLAM
Two robots, one map.
Robot BRobot A24 ORB matches
BAagree
72%walls agree
2.39°heading error
Results
120 runs. 30 houses.
Every run is scored against the true house, which the robots never get to read. The runs use our headless simulator and the same robot brain, with the radio on and off, and with one robot or two.
580 of 600people found (97%)
96%of rooms entered997 of 1,036
95%of the floor searched, median run
715 of 721confirmations correct (99%)
How it's built
OpenCV 5 sees. An agent decides. AWS runs it.
On every dog
01
Sense
Lidar, depth and heat cameras in our Unity simulator.
02
Seewith OpenCV 5
- RGB-D odometry
cv2.Odometry - Warm-shape contours
findContours - Thermal colour
applyColorMap - Keypoints for SLAM
ORB
03
Decide
A language-model agent picks the next room or the next look.
04
Act and share
Reflexes back off from heat at once. It can spray water on a small fire. The radio merges maps.
What it sees changes what it does next
On AWS
AWS AmplifyHosts this site
AWS Lambda on GravitonOpenCV 5 vision API, arm64
Amazon ECS on FargateThe robots' agent service, arm64